软体果冻雨
Softbodies,Niklas Niehus (holtsetio),2025 年
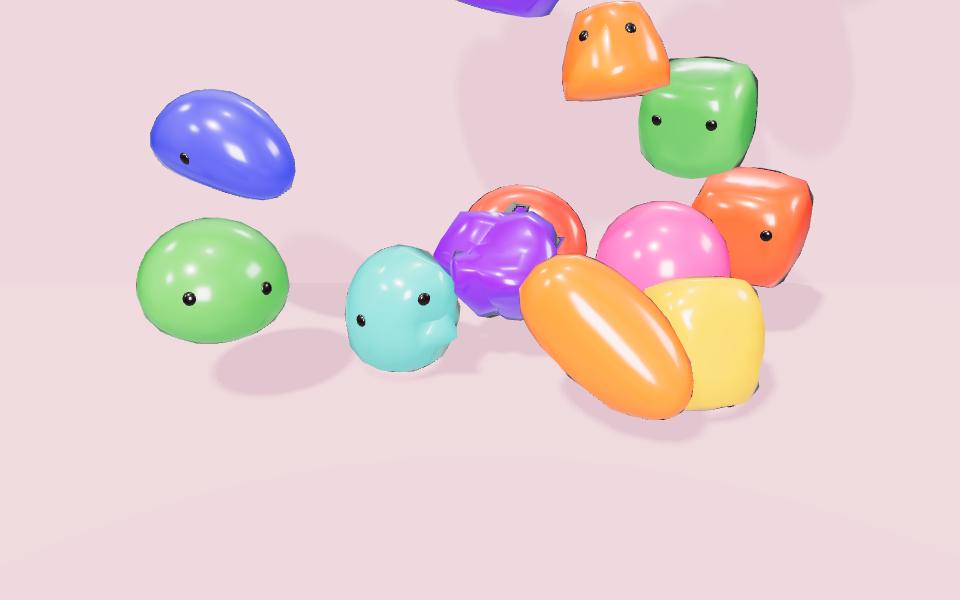
正在布展…
它是怎么做的
- 第 1 步每个软体被四面体化,表面网格通过重心坐标“蒙皮”到四面体上
- 第 2 步有限元(FEM)约束在 TSL 计算着色器中并行求解
- 第 3 步空间网格哈希用于检测不同软体之间的碰撞
- 第 4 步实例化渲染所有软体,并配合阴影与环境光
复刻配方
一段技术配方,可以直接交给 AI 编程助手,也可以自己照着写。想指定技术栈、位置和性能预算,就把它加入实现方案。
Tetrahedralise a few source meshes and store tet vertex positions, velocities and rest-shape matrices in storage buffers. Each substep, predict positions, then in a compute shader evaluate a corotated or Neo-Hookean FEM constraint per tetrahedron and apply position corrections, followed by a ground and wall collision pass. Build a uniform spatial hash grid of vertices for soft-soft collisions and push overlapping vertices apart. Skin the visible surface mesh to the tets with barycentric weights and draw all bodies instanced.
档案
性能开销
视觉强度
实现难度
尺度为策展判断(1 到 5),用于比较和推荐。
核实记录:Opened https://holtsetio.com/lab/softbodies/ (200, title 'Softbodies - ThreeJS WebGPU Experiment - holtsetio.com'); repo holtsetio/softbodies exists, licence MIT via GitHub API; README credits TetSim by Johnathon Selstad.
相关藏品
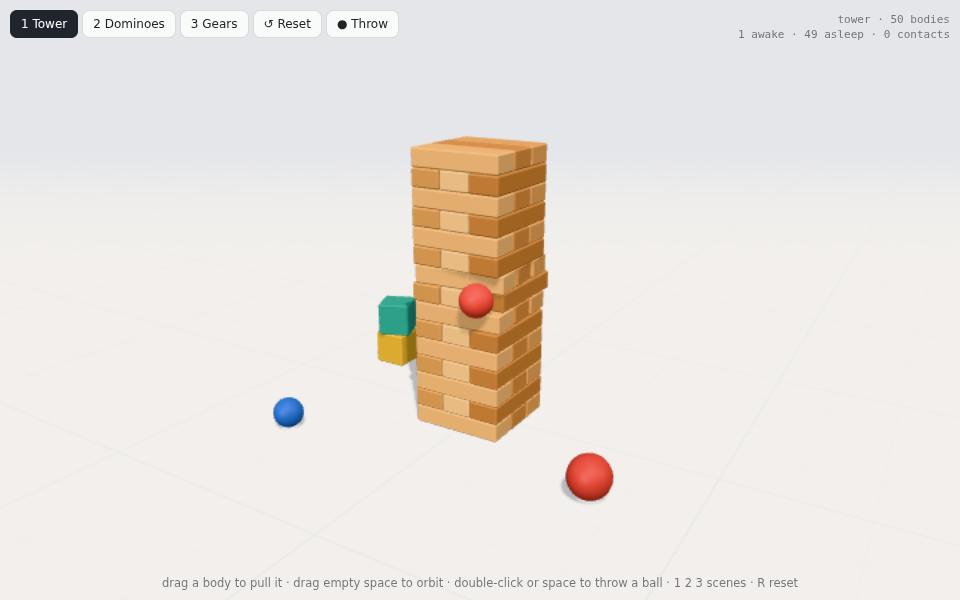
多引擎物理实验室
2021Phy — lo-th
一个物理沙盒合集:布娃娃、车辆、堆叠方块、软体……还能在 Oimo、Ammo、Rapier、Jolt 等物理引擎间一键切换。
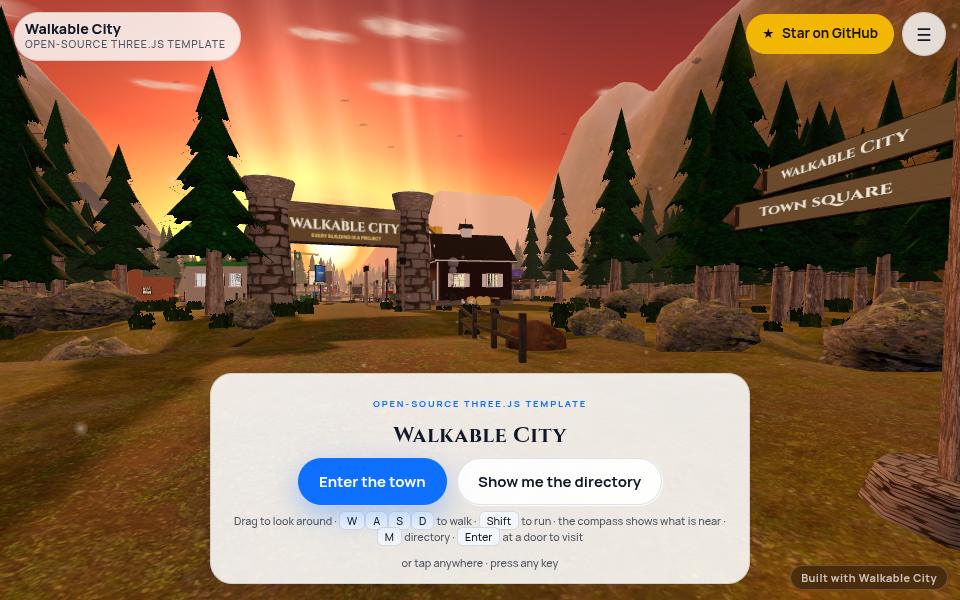
可漫步的小镇
2026Walkable City (engine behind Client City) — John Bailey / The Bailey Perspective
夕阳下的山谷小镇,每栋房子是一件作品,沿着河流、松林和石桥走过去就能逛完整个作品集。
代码仓库美术馆
2026Git Gallery — William Welsh (usr-wwelsh)
第一人称走进一座由 GitHub 主页生成的珍奇柜:大厅墙上是贡献热力图,走廊两侧每个仓库一间展厅。